Ir para o conteúdo

Esta página é uma tradução automática oferecida para sua conveniência. A versão em inglês é a que prevalece. Ler em inglês

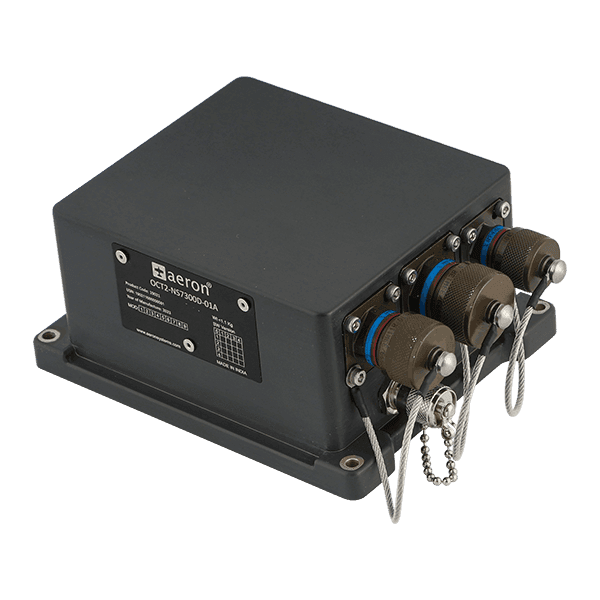
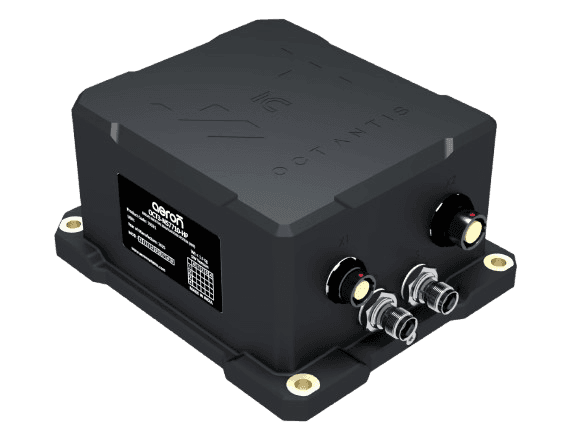
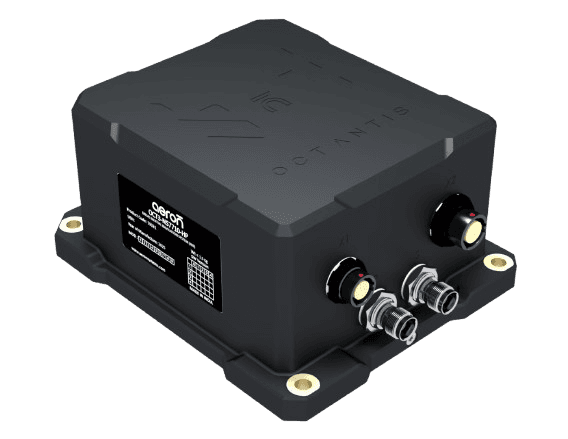
OCT3-NS7710-HP

Sistemas de navegação inercial

Aeron OCT3-NS7710-HP
  • Navigation Update Rate100 Hz
  • RTK Horizontal Accuracy<1 cm
  • GNSS-Denied Performance0.3%
  • Gyro Bias Instability<0.5°/hr

Encontre a solução ideal

Responda a uma pergunta para ver quais sistemas de navegação servem para a sua plataforma.

Em qual plataforma você vai implantá-los?

Sua solução: OCT3-NS7710-HP and Octantis 2 INS-GNSS

Aeron OCT3-NS7710-HP

Sua solução

OCT3-NS7710-HP

Dual-Antenna MEMS INS-GNSS

  • Instabilidade de bias do giroscópio0.25 °/hr
  • Precisão de rumo0.3 deg (Single antenna GNSS in dynamic conditions)
  • Peso1500 g

Este é o produto exibido

Octantis 2 INS-GNSS

Sua solução

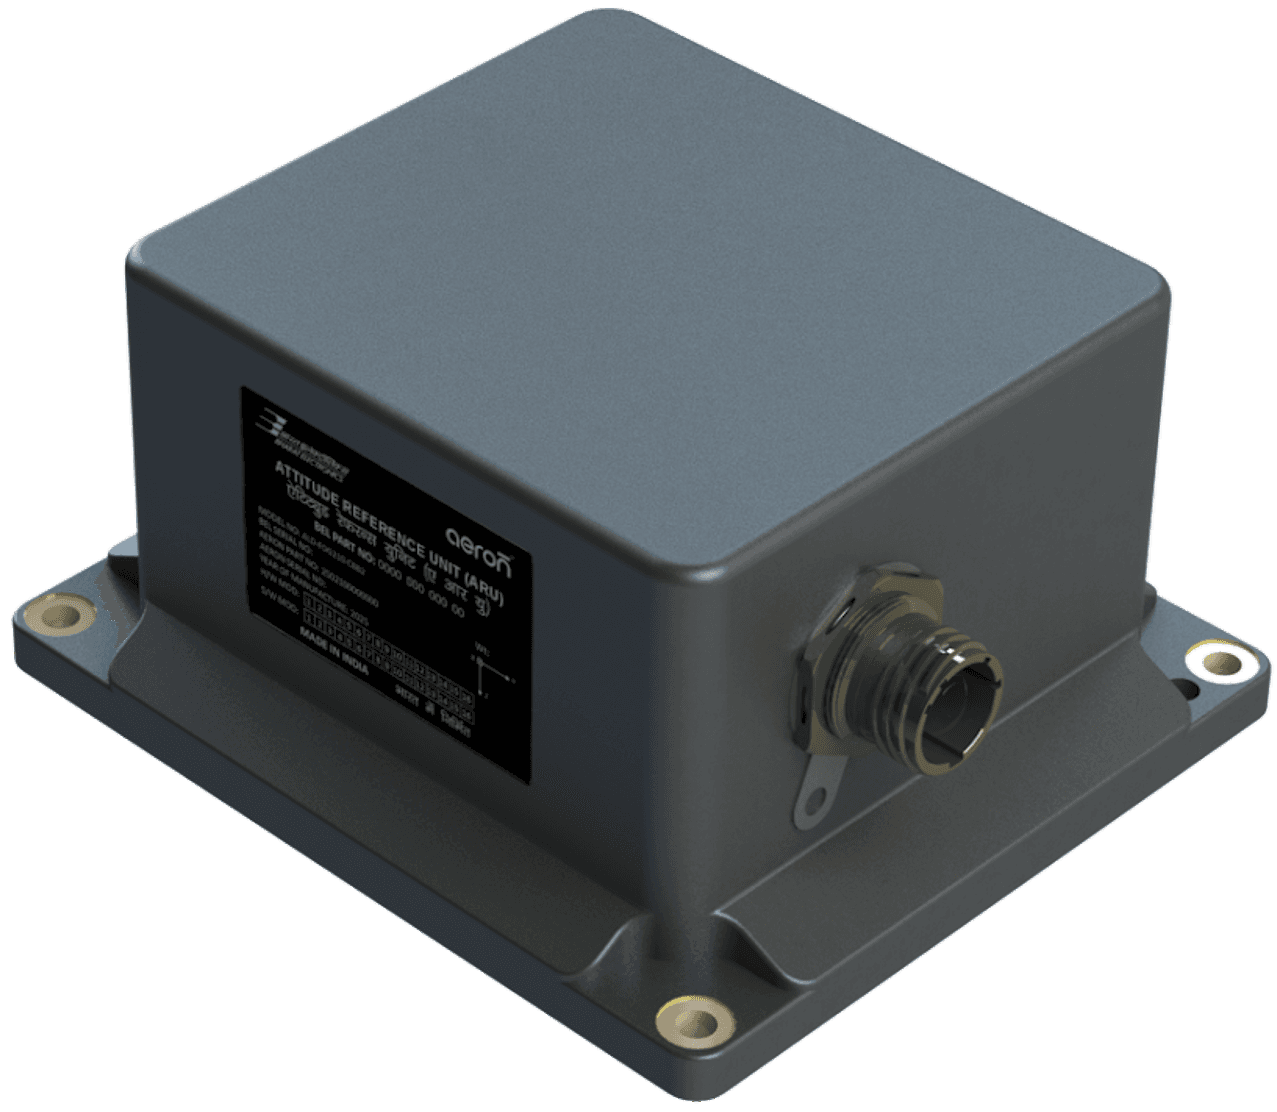
Octantis 2 INS-GNSS

Sistema de navegação inercial robusto e de alta confiabilidade para aplicações terrestres e não tripuladas

  • Instabilidade de bias do giroscópio<1 °/hr (típico)
  • Precisão de rumo<0.3° RMS com GNSS em condições dinâmicas
  • Peso<1.1 kg
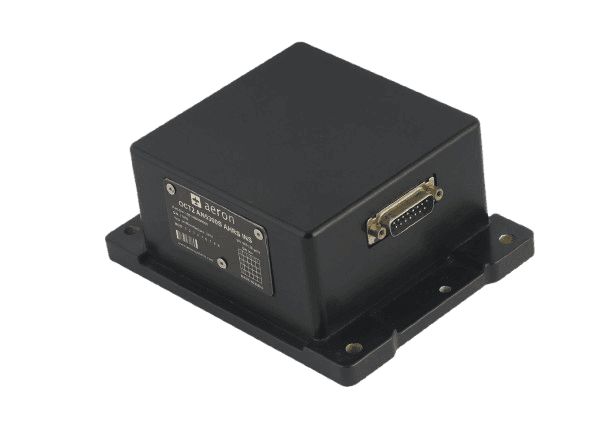
FOG210

Sua solução

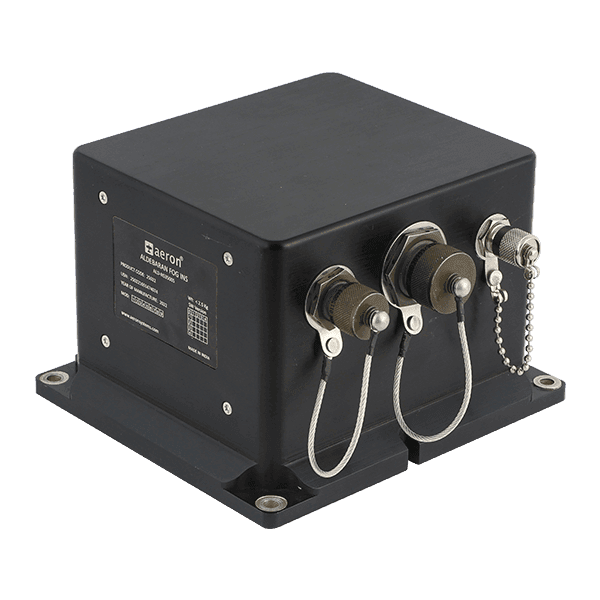
Aldebaran FOG 210

Rugged Two-Axis Digital FOG Systems

  • Instabilidade de bias do giroscópio1 °/hr
  • Angular random walk0.0667 °/√hr
  • Peso1700 gm

OCT3-NS7710-HP

The OCT3-NS7710-HP is a dual-antenna high performance MEMS INS-GNSS system designed to provide highly accurate and reliable navigation and orientation data for a range of mission-critical applications.

How Aeron Inertial Navigators Work?

Every Aeron navigator fuses inertial and GNSS data through the same Extended Kalman Filter approach — only the sensor grade and configuration change between products.

In:

  • IMU & Magnetometer: Tri-axial accelerometer, gyroscope & magnetometer
  • GNSS Receiver: Multi-constellation position & velocity
  • External Aiding: Speed, velocity, position, altitude, heading, magnetometer
Sensor Fusion Engine: Extended Kalman Filter (NavPro)

Out:
  • Position & Velocity: GNSS-aided position & velocity output
  • Attitude & Heading: Euler angles, roll, pitch, yaw
  • Health & Diagnostics: Built-in test & sensor status

Features

  • Dual Antenna GNSS Compassing

    Accurate true heading from the outset, independent of motion or magnetometers, using dual-antenna configuration.

  • FOG-Grade MEMS Performance

    High-precision inertial sensors with <0.5°/hr bias instability gyroscope, delivering tactical-grade performance.

  • RTK Precision Positioning

    RTK positioning accuracy <1 cm for robotics, autonomous mobility, and precision surveying.

  • GNSS-Denied Robustness

    Continuous navigation in GNSS-denied environments, including urban canyons, foliage, and under-jamming. Achieves 0.3% DT with odometer aiding.

  • Advanced Sensor Fusion

    Extended Kalman Filter (NavPro) combining inertial and satellite data for seamless transitions between GNSS-available and denied scenarios.

  • MIL Qualified Design

    Compliant to MIL-STD-810H (environmental), MIL-STD-461G (EMI/EMC), MIL-STD-1275F and MIL-STD-704F (power supply).

  • Resistance to Interference

    Multi-frequency, multi-constellation GNSS (L1/L2/L5) with safeguard against intentional jamming and spoofing.

  • Multiple Supported Interfaces

    Wide array of interface options: RS-232, RS-422, CAN, Ethernet, with NMEA 0183, Binary, and J1939 protocols.

  • Rugged Design

    Cost-effective, rugged, and field-deployable solution with operational survival shock compliance.

Technical specifications

OCT3-NS7710-HP

Interfaces

RS-232 (Isolated)Data Output (Binary/NMEA), GUI interface, External Aiding inputup to 921600 baudrate
RS-232 - RTK (Isolated)RTK inputup to 460800 baudrate
RS-422 (Isolated)Data Output (Binary/NMEA), GUI interface, External Aiding inputup to 921600 baudrate
CAN (Isolated)CAN Data Output, External Speed and Gear Data InputJ1939 format (250 Kbps)
Ethernet (Isolated)Data Output (Binary/NMEA)100 Mbps
OutputEuler Angles (Yaw, Pitch, Roll); Quaternion; Position; Velocity; Acceleration, Angular Rate, Time, GNSS parameters, Sensor parameters, Health status
External Aiding InputsSpeed, Velocity, Position, Altitude, Heading, Magnetometer
Output data protocolsNMEA 0183 (version 4.11), Binary (Aeron Standard Binary Protocol), J1939
Input data protocolsAiding: Aeron Standard Binary Aiding Packet RTK Correction: RTCM v2.3, RTCM v3.2, CMR, CMR+
Built-In TestsPower-ON Built-in Test (PBIT) Continuous Built-in Test (CBIT)
Update Rate (Configurable upto)500 Hz (Sensor parameters) · 100 Hz (Navigation parameters)

Electrical and Environmental

Input voltage+12 to +32 VDCIsolated
Power consumption7.3 WTolerance ±1W
Digital Input Voltage+5 to +32 VDC
Digital Output Voltage+5 VDC
Operating temperature-40 to +71 ºC
Storage temperature-55 to +85 ºC
Survival ShockOperational (Functional Shock) - 40g at 11ms; Non-Operational (Crash Hazard Shock) - 75g at 6msAs per MIL-STD-810H
Ingress ProtectionIP65
Power Supply ProtectionAs per MIL-STD-704F, MIL-STD-1275F
EMI/EMCAs per MIL-STD-461G
Environmental TestsAs per MIL-STD-810H

Angular Rate

Range±325 °/s
Bias Instability0.25 °/hrTypical
Bias Repeatability7 °/hrTypical
Noise Density0.0003 °/s/√HzTypical
ARW0.04 °/√hrTypical
Scale Factor Accuracy600 ppmTypical
Non-Linearity100 ppmTypical

Accuracy

Roll, Pitch0.02 deg (Static) · 0.05 deg (Dynamic)
Heading0.5 deg (Magnetometer) · 0.3 deg (Single antenna GNSS in dynamic conditions) · 0.1 deg (Dual antenna @ 1.0 m antenna separation) · 0.02 deg (Dual antenna @ 5.0 m antenna separation)
Velocity0.03 m/s
Horizontal Position0.8 cm (RTK) · 1.5 m (Standalone) · 1 m (SBAS) · 0.3 % (DT with odometer aiding)
Vertical Position<2 cm (RTK) · 3 m (Standalone) · 2 m (SBAS)
Vertical Position (with Baro.)2 m1σ relative (with barometer)

Acceleration

Range±20 g
Bias Instability25 μgTypical
Bias Repeatability1.7 mgTypical
Noise Density15 μg/√HzTypical
VRW0.03 m/s/√hrTypical

Aiding

Internal GNSSGPS L1CA/L1P/L1C/L2P/L2C/L5 GLONASS G1/G2/G3, P1/P2 BeiDou B1i/B2i/B3i/B1C/B2a/B2b/AceBOC GALILEO E1BC/E5a/E5b/E6BC/AltBOC NavIC (IRNSS) L5
Correction and Signal InformationSBAS, RTK
TTFF Cold Start30 secTypical
Hot Start<10 secTypical
Connector2 x TNC Female Connector (Amphenol make P/N: 122428)

Attitude

Roll Range±180 deg
Pitch Range±90 deg
Heading Range±180 deg
Angle Resolution<0.01 deg

Mechanical

Weight1500 gTolerance ±75 g
Dimensions156 (L) x 129 (W) x 74 (H) mmTolerance ±0.5 mm
Fixation boltsM6 metric
Connector12 Pin Receptacle - ODU AMC® Connector - GK2YAR-PDMUF00-000L 12 Pin Mating - ODU AMC® Connector - S12YAR -PDMXFG0-0000 19 Pin Receptacle - ODU AMC® Connector - GKAYAR-P19UC00-000L 19 Pin Mating - ODU AMC® Connector - S1AYAR -P19XCD0-0000

GNSS Parameters

Maximum Altitude18,288 m
Maximum Speed513.9 m/s

Barometer

Range300-1250 hPa
Noise density0.02 - 0.9 Pa

Magnetometer

Range±8 gauss
Noise density0.002 Gauss/√Hz

I/O

Digital Input (2 Channels)DI1 (Odometer input) (Configurable Scaling) (Isolated, Max Frequency: 10 KHz) · DI2 (Reserved) (Isolated)
Digital Output (3 Channels)1PPS · DO1: GNSS fix type indicator · DO2: Device health indicatorIsolated

Applications

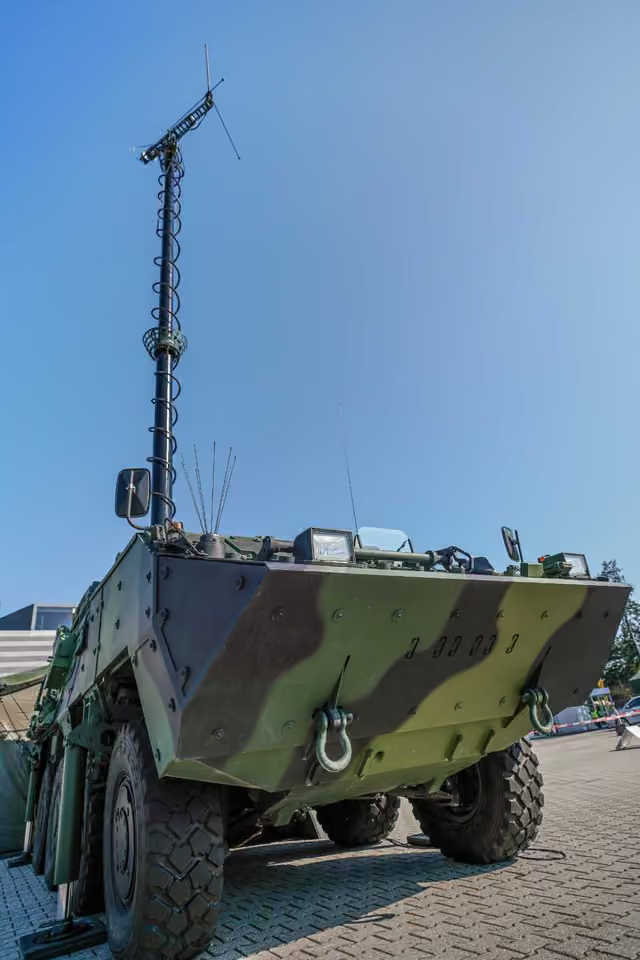
  • Armoured vehicles : Aeron SystemsArmoured vehicles
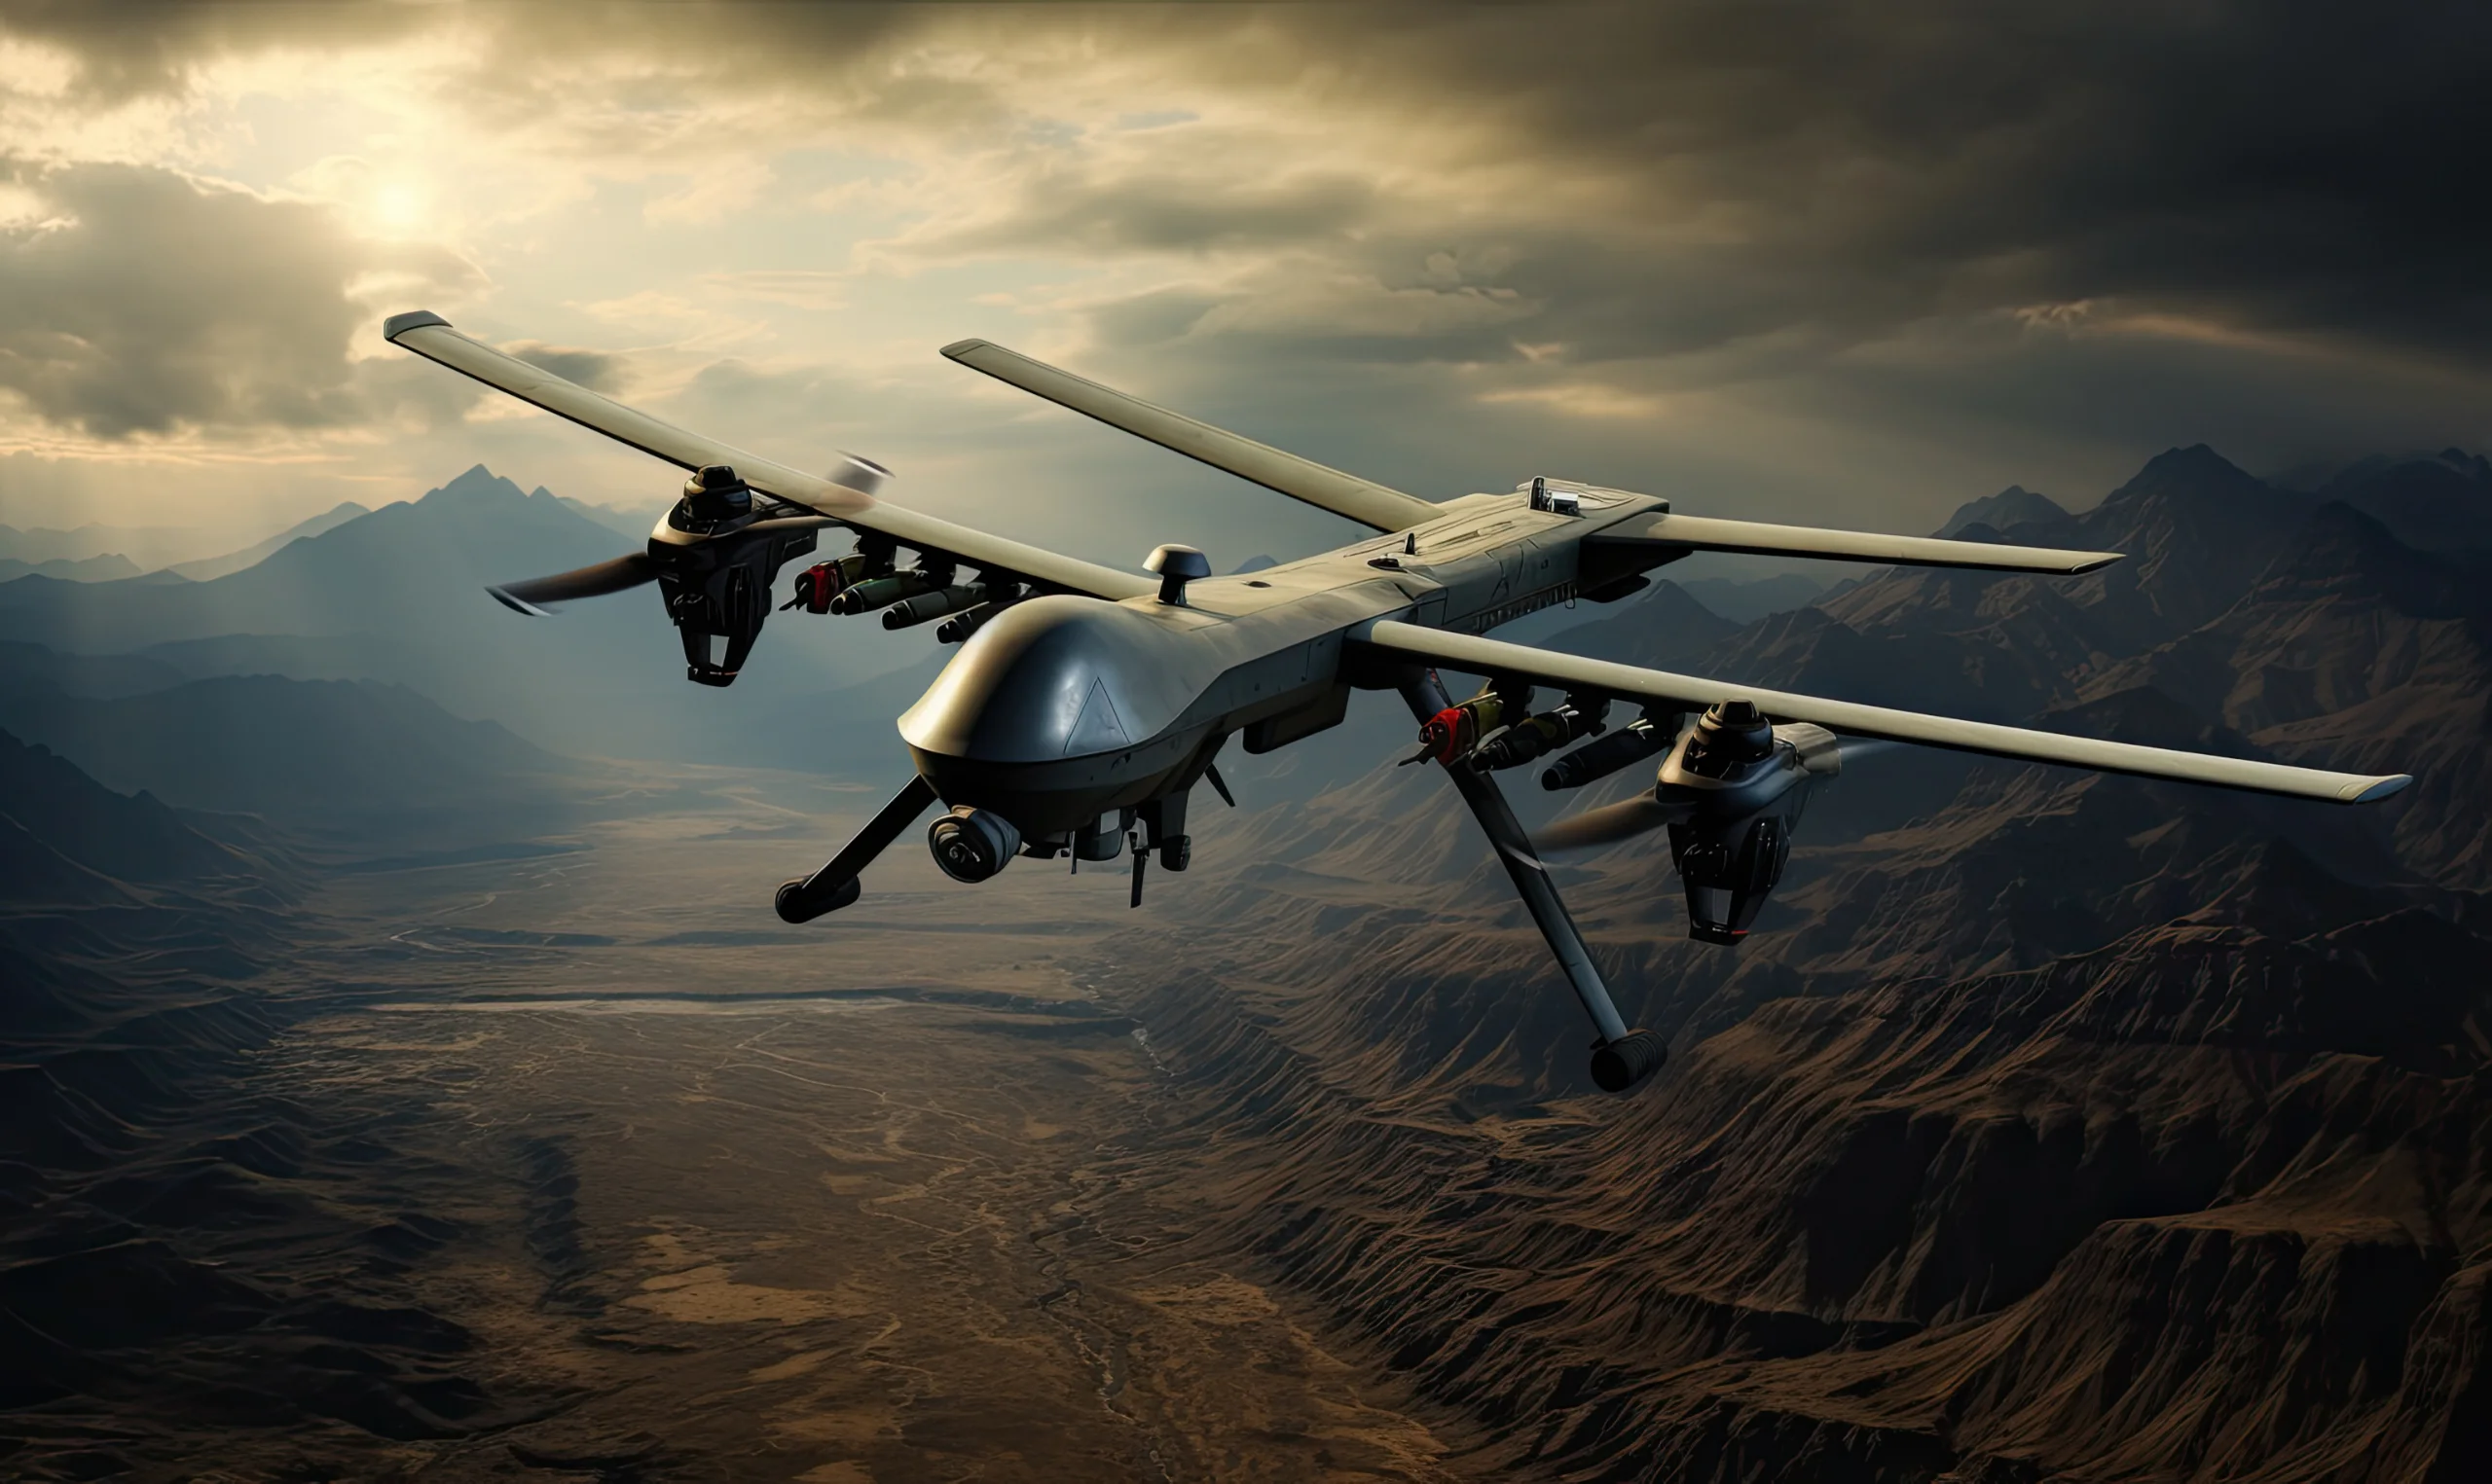
  • Unmanned Aerial Vehicles (UAVs) : Aeron systemsUnmanned Aerial Vehicles (UAVs)

Perguntas

Common questions about the OCT3-NS7710-HP .

Can the system operate during GNSS signal loss?

Yes, it navigates using inertial dead reckoning and achieves 0.3% DT with odometer aiding.

Which types of inertial sensor does the OCT3-NS7710-HP use?

It integrates high-performance MEMS gyros and accelerometers with <0.5°/hr bias instability gyroscope.

Is the system suitable for UAV applications?

Yes, the system is compatible with multiple domain platforms including UAVs, armoured vehicles, and mobile platforms.

Can the system withstand harsh environmental conditions?

Yes, it is built to MIL-STD-810H specifications, with IP65 ingress protection and operating from -40°C to +71°C.

What type of communication interfaces does the OCT3-NS7710-HP support?

It supports standard interfaces such as RS-232, RS-422, CAN, Ethernet, with NMEA 0183, Binary, and J1939 protocols.

Does the system reduce navigation drift?

Yes, it uses Aeron's proprietary NavPro Kalman filter algorithm and aiding sensors to arrest navigation drift, achieving <0.3% DT (1σ) in GNSS-denied conditions.

Contato

Peça um preço do OCT3-NS7710-HP ou converse com um de nossos engenheiros sobre a sua aplicação.

Escritórios

Índia

Sede e centro de projetos, Pune

Plot No. 7, Lane No. 5, Laxman Nagar, Balewadi
Pune, Maharashtra 411045, India

Abrir no Google Maps

Planta de fabricação, Pune

Vivan Kohli Industrial Park, Shed No. 5, Gat No. 446
Old Pune-Mumbai Highway, Naigaon, Kanhe Phata, Talegaon
Pune, Maharashtra 412106, India

Abrir no Google Maps

Vendas e suporte, Bengaluru

First Floor, Building No. 11, Sai Anugraha
Jeevan Bhima Nagar Main Road
Bengaluru, Karnataka 560075, India

Abrir no Google Maps

Vendas e suporte, Vijayawada

Door No. 52-1/4-8D, Plot No. 9, 5th Cross Road
Veterinary Colony
Vijayawada, Andhra Pradesh 520008, India

Abrir no Google Maps

Internacional

Aeron Systems Pvt. Ltd., Sharjah

Saif Executive Office # P8-17-02
Sharjah Airport International Free Zone Authority
PO Box 8000, Sharjah, U.A.E.

Abrir no Google Maps