Your match
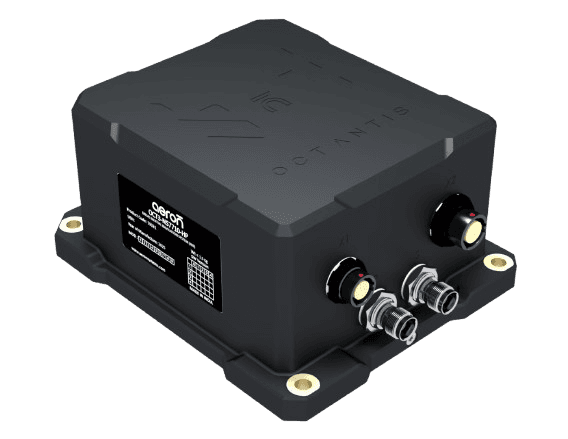
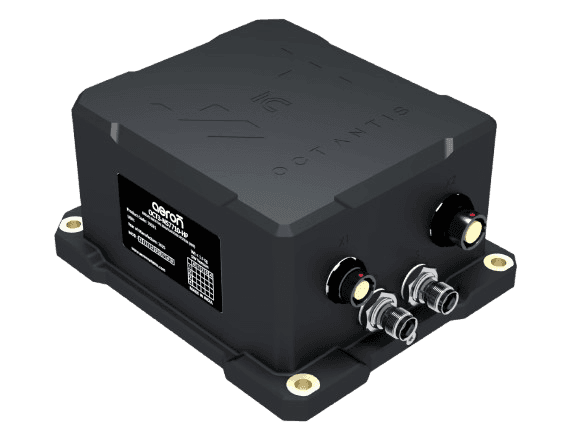
OCT3-NS7710-HP
Dual-Antenna MEMS INS-GNSS
- Drift without GNSS0.3 % (DT with odometer aiding)
- Gyro bias instability0.25 °/hr
- Weight1500 g
This is the product on show
Read how it solves itGNSS-denied navigation for armoured vehiclesInertial Navigation Systems
Dual-Antenna MEMS INS-GNSS
Answer one question to see which navigation systems fit your platform.
What platform are you deploying on?
Your match: OCT3-NS7710-HP and Octantis 2 INS-GNSS
Your match
Dual-Antenna MEMS INS-GNSS
This is the product on show
Read how it solves itGNSS-denied navigation for armoured vehicles
Your match
Rugged High Reliability Inertial Navigation System for Land and Unmanned Applications
Your match
Dual-Antenna MEMS INS-GNSS
This is the product on show
Your match
Rugged High Reliability Inertial Navigation System for Land and Unmanned Applications
Your match
Superior tactical Fibre-Optic Gyro based Inertial Navigation System
Your match
Rugged Two-Axis Digital FOG Systems
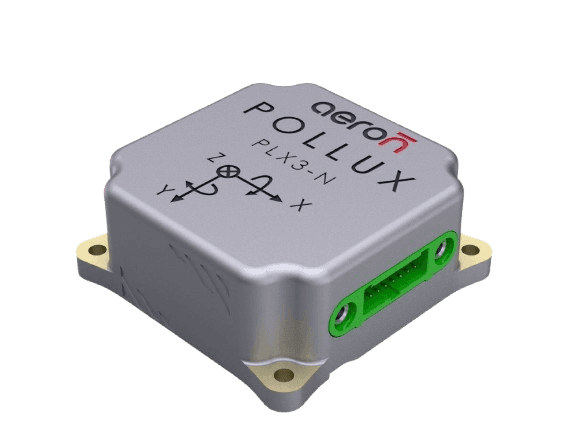
Your match
Micro-miniature Inertial Navigation system
Your match
Rugged Dual Antenna Inertial Navigation System for Unmanned and Land Applications
The OCT3-NS7710-HP is a dual-antenna high performance MEMS INS-GNSS system designed to provide highly accurate and reliable navigation and orientation data for a range of mission-critical applications.
How Aeron Inertial Navigators Work?
Every Aeron navigator fuses inertial and GNSS data through the same Extended Kalman Filter approach — only the sensor grade and configuration change between products.
In:
Accurate true heading from the outset, independent of motion or magnetometers, using dual-antenna configuration.
High-precision inertial sensors with <0.5°/hr bias instability gyroscope, delivering tactical-grade performance.
RTK positioning accuracy <1 cm for robotics, autonomous mobility, and precision surveying.
Continuous navigation in GNSS-denied environments, including urban canyons, foliage, and under-jamming. Achieves 0.3% DT with odometer aiding.
Extended Kalman Filter (NavPro) combining inertial and satellite data for seamless transitions between GNSS-available and denied scenarios.
Compliant to MIL-STD-810H (environmental), MIL-STD-461G (EMI/EMC), MIL-STD-1275F and MIL-STD-704F (power supply).
Multi-frequency, multi-constellation GNSS (L1/L2/L5) with safeguard against intentional jamming and spoofing.
Wide array of interface options: RS-232, RS-422, CAN, Ethernet, with NMEA 0183, Binary, and J1939 protocols.
Cost-effective, rugged, and field-deployable solution with operational survival shock compliance.
| RS-232 (Isolated) | Data Output (Binary/NMEA), GUI interface, External Aiding inputup to 921600 baudrate |
|---|---|
| RS-232 - RTK (Isolated) | RTK inputup to 460800 baudrate |
| RS-422 (Isolated) | Data Output (Binary/NMEA), GUI interface, External Aiding inputup to 921600 baudrate |
| CAN (Isolated) | CAN Data Output, External Speed and Gear Data InputJ1939 format (250 Kbps) |
| Ethernet (Isolated) | Data Output (Binary/NMEA)100 Mbps |
| Output | Euler Angles (Yaw, Pitch, Roll); Quaternion; Position; Velocity; Acceleration, Angular Rate, Time, GNSS parameters, Sensor parameters, Health status |
| External Aiding Inputs | Speed, Velocity, Position, Altitude, Heading, Magnetometer |
| Output data protocols | NMEA 0183 (version 4.11), Binary (Aeron Standard Binary Protocol), J1939 |
| Input data protocols | Aiding: Aeron Standard Binary Aiding Packet RTK Correction: RTCM v2.3, RTCM v3.2, CMR, CMR+ |
| Built-In Tests | Power-ON Built-in Test (PBIT) Continuous Built-in Test (CBIT) |
| Update Rate (Configurable upto) | 500 Hz (Sensor parameters) · 100 Hz (Navigation parameters) |
| Input voltage | +12 to +32 VDCIsolated |
|---|---|
| Power consumption | 7.3 WTolerance ±1W |
| Digital Input Voltage | +5 to +32 VDC |
| Digital Output Voltage | +5 VDC |
| Operating temperature | -40 to +71 ºC |
| Storage temperature | -55 to +85 ºC |
| Survival Shock | Operational (Functional Shock) - 40g at 11ms; Non-Operational (Crash Hazard Shock) - 75g at 6msAs per MIL-STD-810H |
| Ingress Protection | IP65 |
| Power Supply Protection | As per MIL-STD-704F, MIL-STD-1275F |
| EMI/EMC | As per MIL-STD-461G |
| Environmental Tests | As per MIL-STD-810H |
| Range | ±325 °/s |
|---|---|
| Bias Instability | 0.25 °/hrTypical |
| Bias Repeatability | 7 °/hrTypical |
| Noise Density | 0.0003 °/s/√HzTypical |
| ARW | 0.04 °/√hrTypical |
| Scale Factor Accuracy | 600 ppmTypical |
| Non-Linearity | 100 ppmTypical |
| Roll, Pitch | 0.02 deg (Static) · 0.05 deg (Dynamic) |
|---|---|
| Heading | 0.5 deg (Magnetometer) · 0.3 deg (Single antenna GNSS in dynamic conditions) · 0.1 deg (Dual antenna @ 1.0 m antenna separation) · 0.02 deg (Dual antenna @ 5.0 m antenna separation) |
| Velocity | 0.03 m/s |
| Horizontal Position | 0.8 cm (RTK) · 1.5 m (Standalone) · 1 m (SBAS) · 0.3 % (DT with odometer aiding) |
| Vertical Position | <2 cm (RTK) · 3 m (Standalone) · 2 m (SBAS) |
| Vertical Position (with Baro.) | 2 m1σ relative (with barometer) |
| Range | ±20 g |
|---|---|
| Bias Instability | 25 μgTypical |
| Bias Repeatability | 1.7 mgTypical |
| Noise Density | 15 μg/√HzTypical |
| VRW | 0.03 m/s/√hrTypical |
| Internal GNSS | GPS L1CA/L1P/L1C/L2P/L2C/L5 GLONASS G1/G2/G3, P1/P2 BeiDou B1i/B2i/B3i/B1C/B2a/B2b/AceBOC GALILEO E1BC/E5a/E5b/E6BC/AltBOC NavIC (IRNSS) L5 |
|---|---|
| Correction and Signal Information | SBAS, RTK |
| TTFF Cold Start | 30 secTypical |
| Hot Start | <10 secTypical |
| Connector | 2 x TNC Female Connector (Amphenol make P/N: 122428) |
| Roll Range | ±180 deg |
|---|---|
| Pitch Range | ±90 deg |
| Heading Range | ±180 deg |
| Angle Resolution | <0.01 deg |
| Weight | 1500 gTolerance ±75 g |
|---|---|
| Dimensions | 156 (L) x 129 (W) x 74 (H) mmTolerance ±0.5 mm |
| Fixation bolts | M6 metric |
| Connector | 12 Pin Receptacle - ODU AMC® Connector - GK2YAR-PDMUF00-000L 12 Pin Mating - ODU AMC® Connector - S12YAR -PDMXFG0-0000 19 Pin Receptacle - ODU AMC® Connector - GKAYAR-P19UC00-000L 19 Pin Mating - ODU AMC® Connector - S1AYAR -P19XCD0-0000 |
| Maximum Altitude | 18,288 m |
|---|---|
| Maximum Speed | 513.9 m/s |
| Range | 300-1250 hPa |
|---|---|
| Noise density | 0.02 - 0.9 Pa |
| Range | ±8 gauss |
|---|---|
| Noise density | 0.002 Gauss/√Hz |
| Digital Input (2 Channels) | DI1 (Odometer input) (Configurable Scaling) (Isolated, Max Frequency: 10 KHz) · DI2 (Reserved) (Isolated) |
|---|---|
| Digital Output (3 Channels) | 1PPS · DO1: GNSS fix type indicator · DO2: Device health indicatorIsolated |
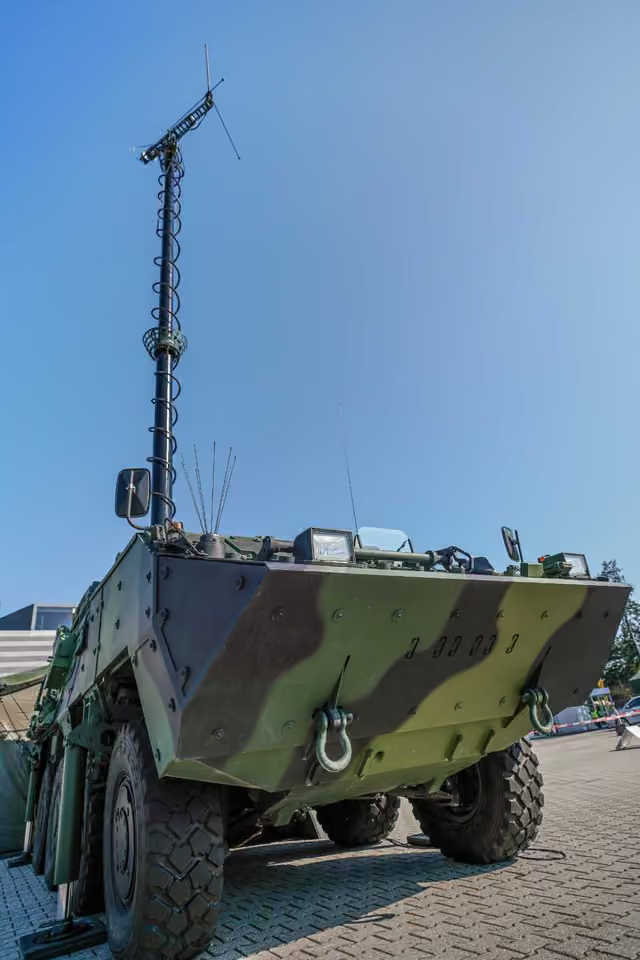 Armoured vehicles
 Unmanned Aerial Vehicles (UAVs)
Common questions about the OCT3-NS7710-HP .
Yes, it navigates using inertial dead reckoning and achieves 0.3% DT with odometer aiding.
It integrates high-performance MEMS gyros and accelerometers with <0.5°/hr bias instability gyroscope.
Yes, the system is compatible with multiple domain platforms including UAVs, armoured vehicles, and mobile platforms.
Yes, it is built to MIL-STD-810H specifications, with IP65 ingress protection and operating from -40°C to +71°C.
It supports standard interfaces such as RS-232, RS-422, CAN, Ethernet, with NMEA 0183, Binary, and J1939 protocols.
Yes, it uses Aeron's proprietary NavPro Kalman filter algorithm and aiding sensors to arrest navigation drift, achieving <0.3% DT (1σ) in GNSS-denied conditions.
Other products from Aerospace & Strategic Electronics, sized by their real dimensions.
172.4 × 155 × 114 mmAldebaran FOG INS-GNSSSuperior tactical Fibre-Optic Gyro based Inertial Navigation System142 × 115 × 65 mmOctantis INS-GNSSRugged High Reliability Inertial Navigation System for Land and Unmanned Applications37 × 37 × 15 mmPollux 3 INS-GNSSMicro-miniature Inertial Navigation system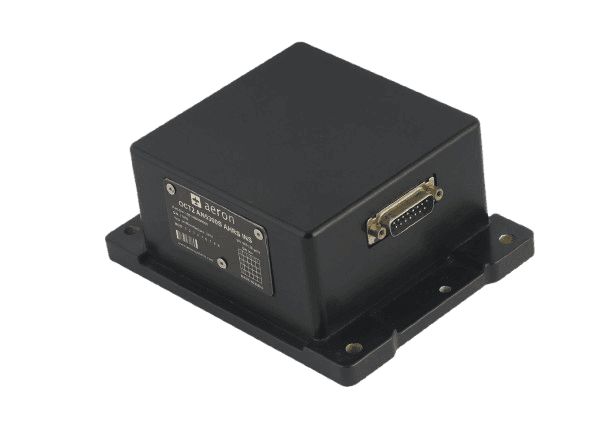 148 × 115 × 63 mmOctantis 2 AN5300S AHRSAirborne Qualified AHRS Systems
Ask for a price on OCT3-NS7710-HP , or talk to one of our engineers about your application.
Sales
Products, quotes and demos
Technical support
Help with an installed product
Careers
Jobs and applications
India
Plot No. 7, Lane No. 5, Laxman Nagar, Balewadi
Pune, Maharashtra 411045, India
Vivan Kohli Industrial Park, Shed No. 5, Gat No. 446
Old Pune-Mumbai Highway, Naigaon, Kanhe Phata, Talegaon
Pune, Maharashtra 412106, India
First Floor, Building No. 11, Sai Anugraha
Jeevan Bhima Nagar Main Road
Bengaluru, Karnataka 560075, India
Door No. 52-1/4-8D, Plot No. 9, 5th Cross Road
Veterinary Colony
Vijayawada, Andhra Pradesh 520008, India
International
Saif Executive Office # P8-17-02
Sharjah Airport International Free Zone Authority
PO Box 8000, Sharjah, U.A.E.