CASTOR IMU 1100
Miniature Tactical 6DOF IMU with RS422 Interface

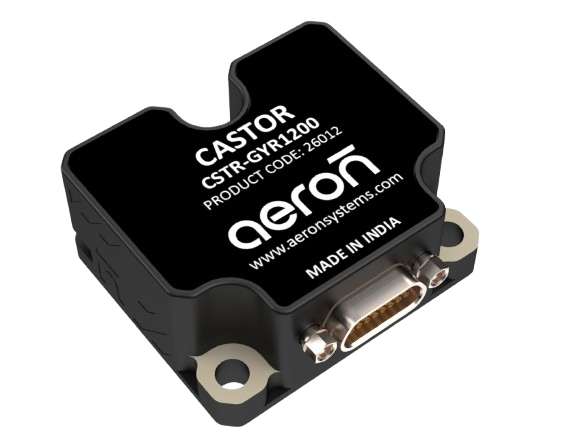
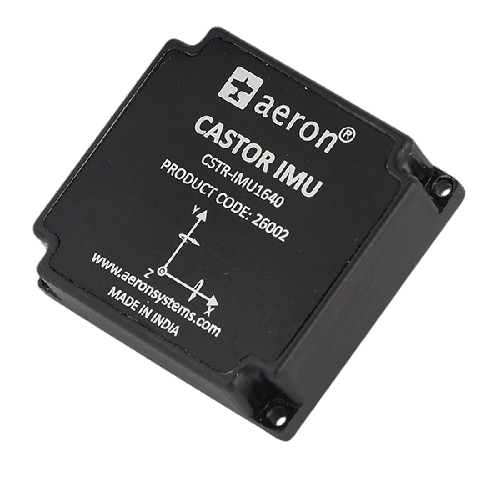
Overview
The Castor series CSTR-IMU1100 is a high-end tactical class inertial measurement unit consisting of high-performance tri-axial accelerometer, tri-axial gyroscope, and tri-axial inclinometer sensors based on the latest MEMS technology, delivering control-grade inertial measurement data over an RS422 interface.
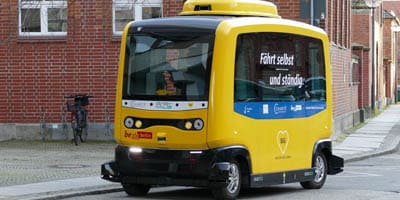
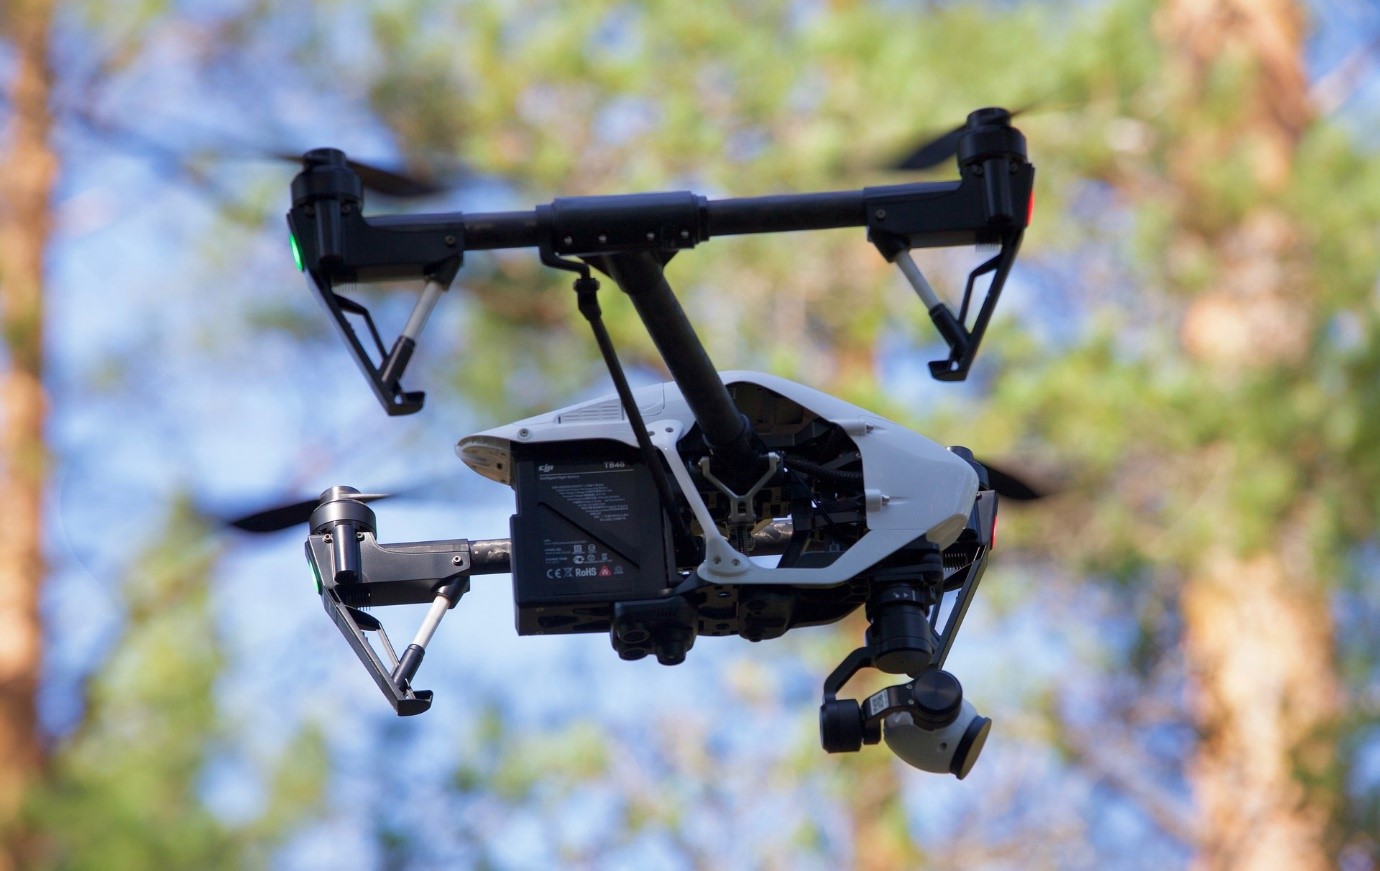
Its rugged and modular design, with output available over an RS422 interface, makes the IMU 1100 suitable for integration with control computers and other application hardware in guidance, navigation, and control systems, robotics and gimbal control, unmanned ground vehicles, and flight control systems.
Design Highlights
How Castor IMU 1100 Processes Sensor Data
Raw accelerometer, gyroscope, and inclinometer signals are calibrated, temperature-compensated, and digitally filtered in real time before being delivered as control-grade inertial data over RS422.
Everything Built for Tactical-Grade Reliability
Shared engineering DNA across the Castor family — factory calibration, digital filtering, and rugged MIL-qualified construction.
Technical Specifications
Castor IMU 1100 · CSTR-IMU1100 · Datasheet v 1.5
Range
±10 g
Bias Instability
0.020 mg (typ.) — 0.016 to 0.024 mg (At 25°C)
Velocity Random Walk (VRW)
0.018 m/s/√hr (typ.) — 0.018 to 0.028 (262 Hz LPF, at 25°C)
Bias Repeatability
±1.5 mg
Bandwidth
262 Hz, −3dB
Noise Density
0.0001 m/s² / √Hz
Resolution
24 bits
Where Castor IMU 1100 Delivers
Field-proven precision across guidance, navigation, and control platforms.
Compare the Castor Family
IMU 1100, GYR 1200, and IMU 1640 — every spec, side by side, no need to switch tabs.
| Sensor Suite | |||
Sensors | Accelerometer, Gyroscope, Inclinometer | Gyroscope only | Accelerometer, Gyroscope |
Gyro Bias Instability GYR 1200's single-axis-family design delivers the lowest gyro bias instability in the range | 0.7°/hr (typ.) | Best 0.6°/hr (typ.) | 1°/hr (typ.) |
Accelerometer Bias Instability | 0.02 mg (typ.) | — | 0.019 mg (typ.) |
Update Rate | Up to 2000 Hz | Up to 2000 Hz | Best Up to 4250 Hz |
| Communication & Interface | |||
Interface | RS422 | RS422 | SPI (15 Mbps) |
Data Format | Binary | Binary | Binary |
Mounting | Standalone module | Standalone module | OEM PCB-mount (board-to-board connector) |
| Electrical & Power | |||
Input Voltage | 4.5 to 5.5 V DC | 4.5 to 5.5 V DC | 3 to 3.6 V DC |
Power Consumption | < 1.3 W | 1.2 W | Best < 1 W |
| Mechanical & Environmental | |||
Dimensions | 38.6 × 44.8 × 21.5 mm | 37.6 × 43.8 × 19 mm | 47 × 44 × 14 mm |
Weight | 72 ± 3 g | 60 ± 4 g | Best 57 ± 3 g |
Mechanical Shock All three qualified per MIL-STD-883F, Method 2002.4, Test Condition B | 1500 g / 0.5 ms half-sine | 1500 g / 0.5 ms half-sine | 1500 g / 0.5 ms half-sine |
Operating Temperature | −40°C to +85°C | −40°C to +85°C | −40°C to +71°C |
Ingress Protection | IP65 | IP65 | IP65 |
| Explore & enquire | Download Datasheet | Download Datasheet | Download Datasheet |
Documents & Resources
Documentation
Castor Family
Castor IMU 1100 — Datasheet
CSTR-IMU1100 · Product Code: 26008
Castor GYR 1200 — Datasheet
CSTR-GYR1200 · Product Code: 26012
Castor IMU 1640 — Datasheet
CSTR-IMU1640 · Product Code: 26002
Frequently
Asked
Questions
Common questions about the Castor IMU 1100.