The Real Problem
Modern positioning systems have a quiet dependency problem. Ask most systems how they work and, underneath the confident answer, there is a satellite signal doing almost all of the work. Nevertheless it is still one of the precious navigation techniques when you have visibility to the sky. The arrangement is fine right up until the moment it isn't a tunnel, a canyon of high-rise buildings, a stacked interchange, an underground loading bay, and even a deliberate jamming of satellite signals. The signal drops, and the inertial fused position estimate that felt so solid a second ago begins to wander.
The reason it wanders is not mysterious. An inertial system estimates motion by integrating what its gyroscopes and accelerometers report. Along with the motion, the process of integration is also accumulating, every small, slowly changing sensor error, a simple bias here, an enemy there in position estimation that gets summed over time, and for position estimation, it gets summed twice. On the MEMS unit, those errors are large enough that an unaided solution can be off by hundreds of meters within a handful of minutes. That is why the traditional answer to GNSS-denied navigation has been to reach for better hardware like navigation-grade fibre-optic gyroscope, ring-laser assemblies. They work beautifully and drift slowly, but they are heavy, power-hungry, export-controlled, and priced for programs rather than products.
DriftLoc starts from the opposite premise. Instead of paying for accuracy in the sensor, it earns accuracy by optimally estimating the changing errors in real time and locking the position drift immensely.
What is DriftLocTM
DriftLoc is a navigation algorithm designed to keep an inertial system honest for long stretches without any satellite fix. It runs on a single commodity IMU, a modest embedded processor, and a physics-driven kinematic mathematical model. Rather than trusting the raw IMU measurements, it maintains a running, statistically weighted picture of how much to trust each source at each instant. DriftLoc thinks in a way that, how much of the platform's own behaviour the algorithm is willing to take seriously. A vehicle in motion is constantly saying something about where it is and how it is oriented, in the way it slows, holds still, corners, and settles, and most of that information is quietly discarded by systems that listen only to the accelerometers and gyros. DriftLoc is designed to read those signals continuously and reconcile them against what the sensors report, so that error is caught and corrected as it forms rather than allowed to accumulate. This entire process of establishing mathematical correlations happens in true real-time. It may sound magical, nevertheless, it is deeply mathematical and foundationally based on Bayesian estimations and statistical signal processing.
The Bottom Line
For a long time the trade in inertial navigation was blunt: pay for accuracy at the sensor, or accept that your position falls apart the moment GNSS goes. DriftLoc is a bet that most of the accuracy people were buying in hardware was actually recoverable in algorithm, by learning the sensors continuously with advanced mathematical correlators, seizing every motion, and refusing anything other than the pure kinematics.
The result is near-navigation-grade positioning through the exact conditions that break lesser systems, on hardware measured in grams and tens of dollars rather than kilograms and tens of thousands. Saving the cost, in other words, no longer means giving up the performance.
The Real Test
The Aeron’s tiny MEMS-based INS, Pollux 3 is updated with the DriftLoc Navigation Algorithm. The van test was conducted with the following sequence.
The INS was mounted on Aeron's test van without GNSS antenna
The Pollux 3 was powered on, and 30 seconds of static environment was provided for alignment.
Initial coordinates were provided through the user interface, sourced from the GNSS-aided on-board reference system installed for comparison.
It was a delight to witness the physics and mathematics working exactly as intended, delivering a clean, pure-inertial-derived position from the Pollux 3 in real time.
Test Summary
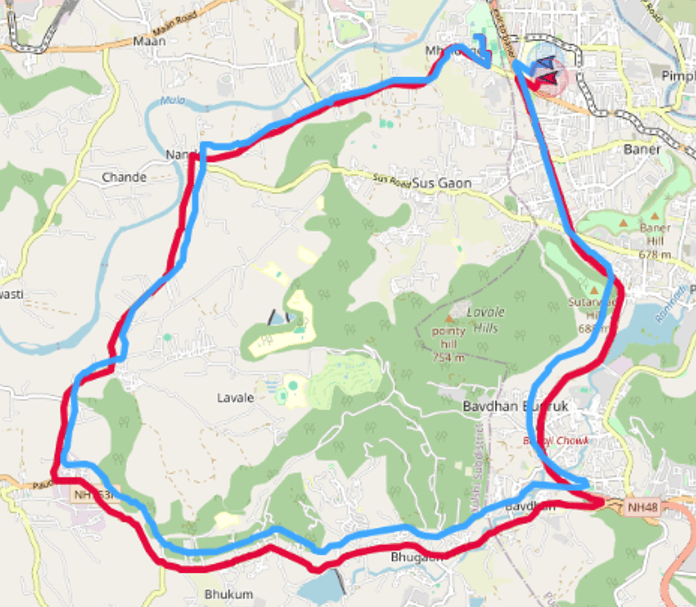 Position Plot of Pollux 3 INS and Reference Unit | 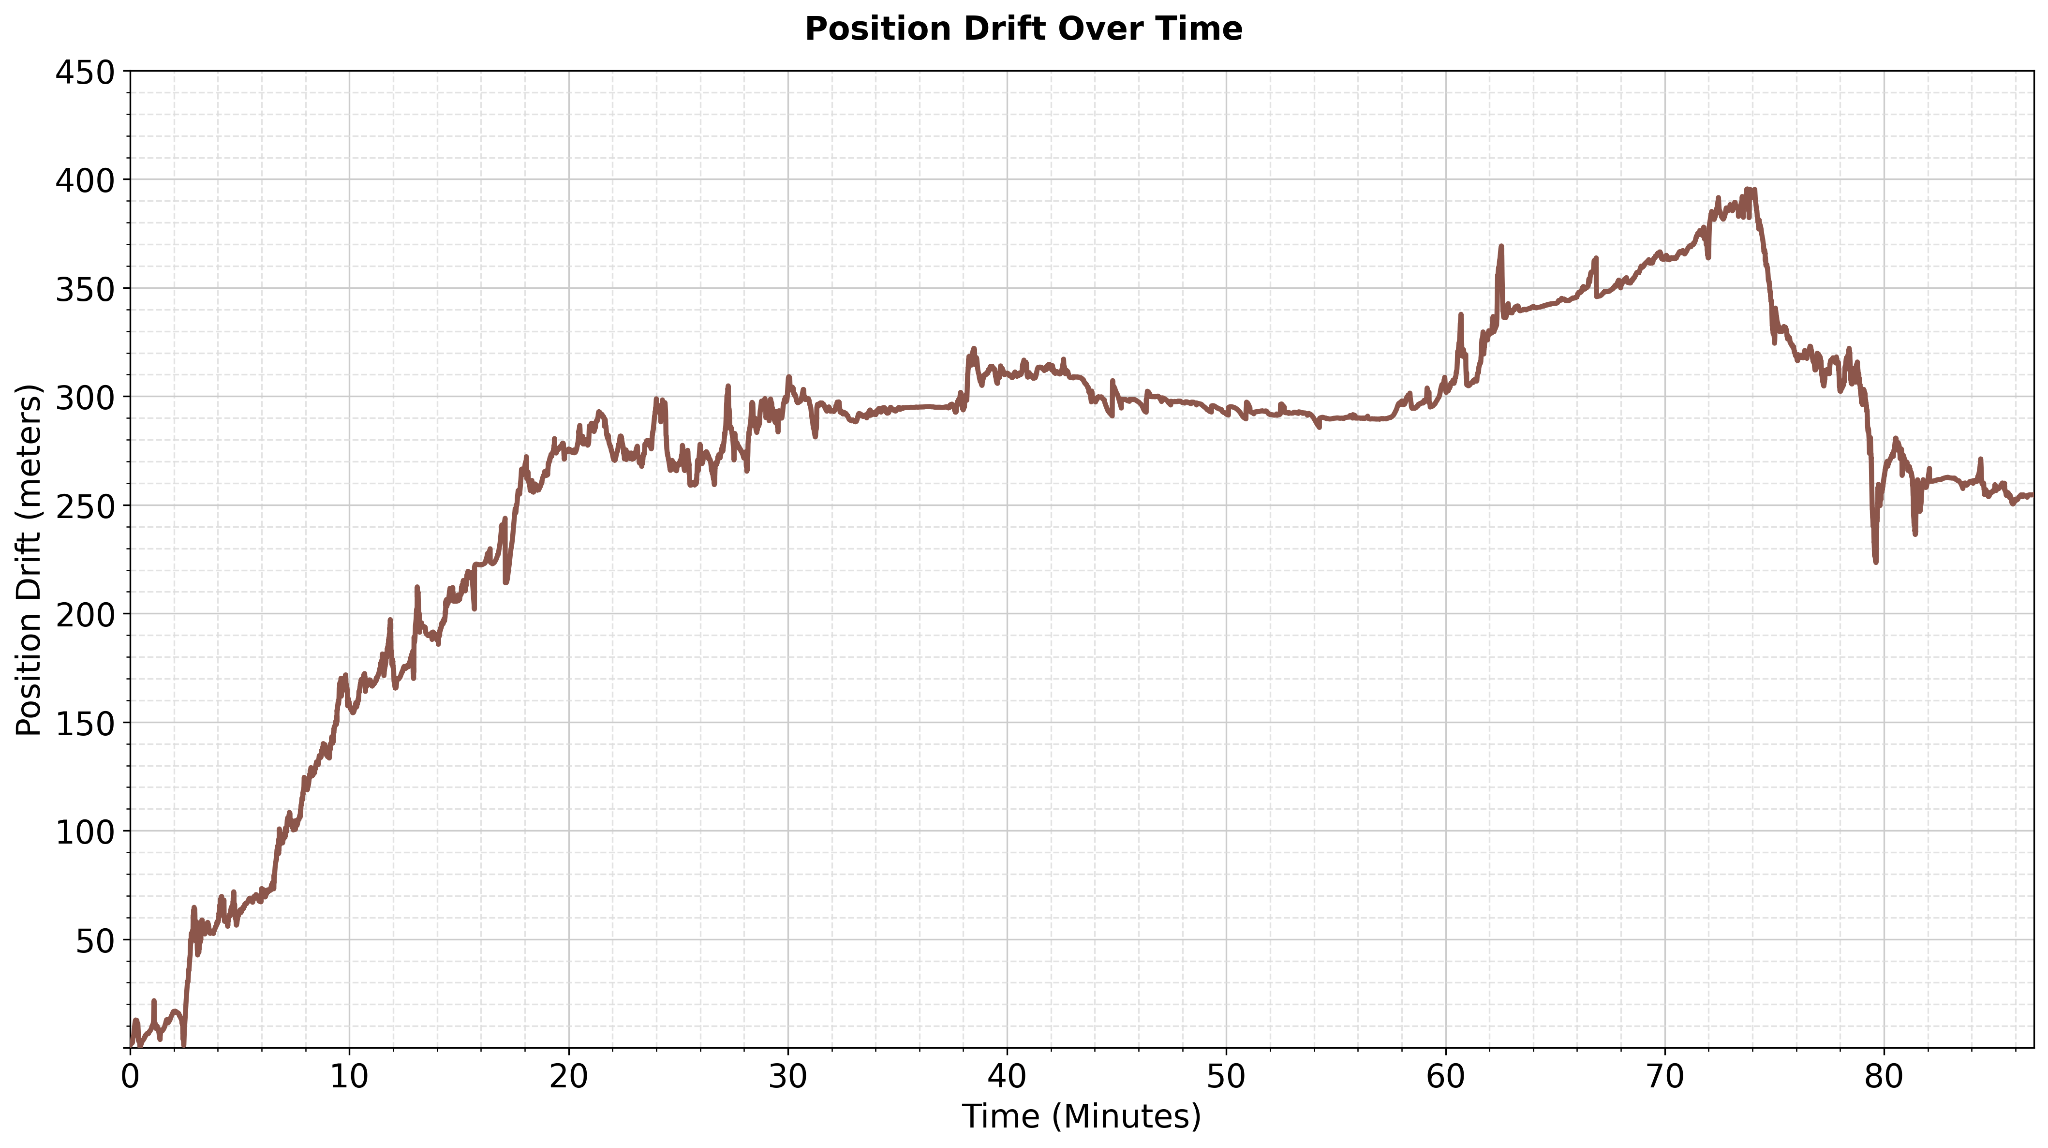 Drift Over Time Plot |
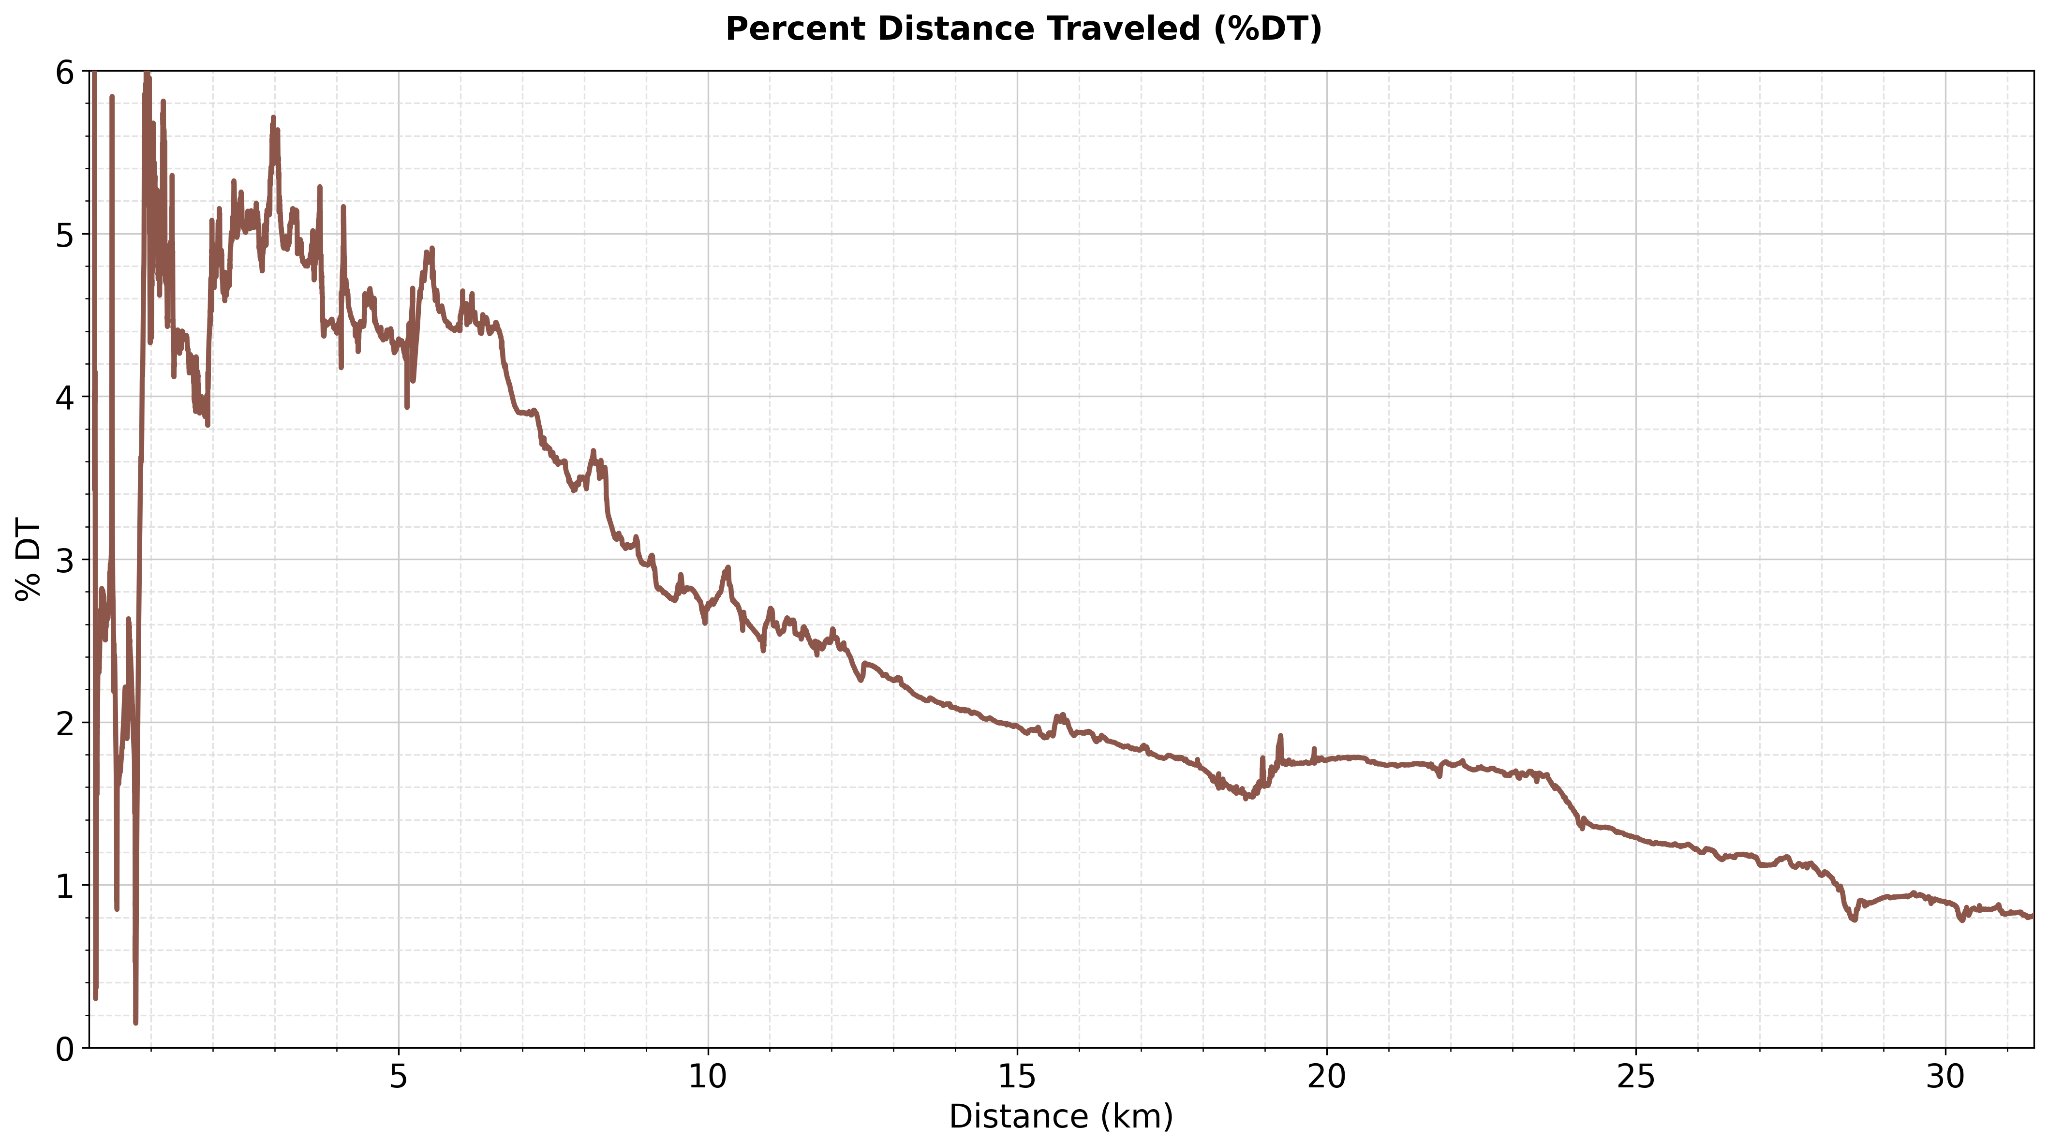 Percent DT Plot | 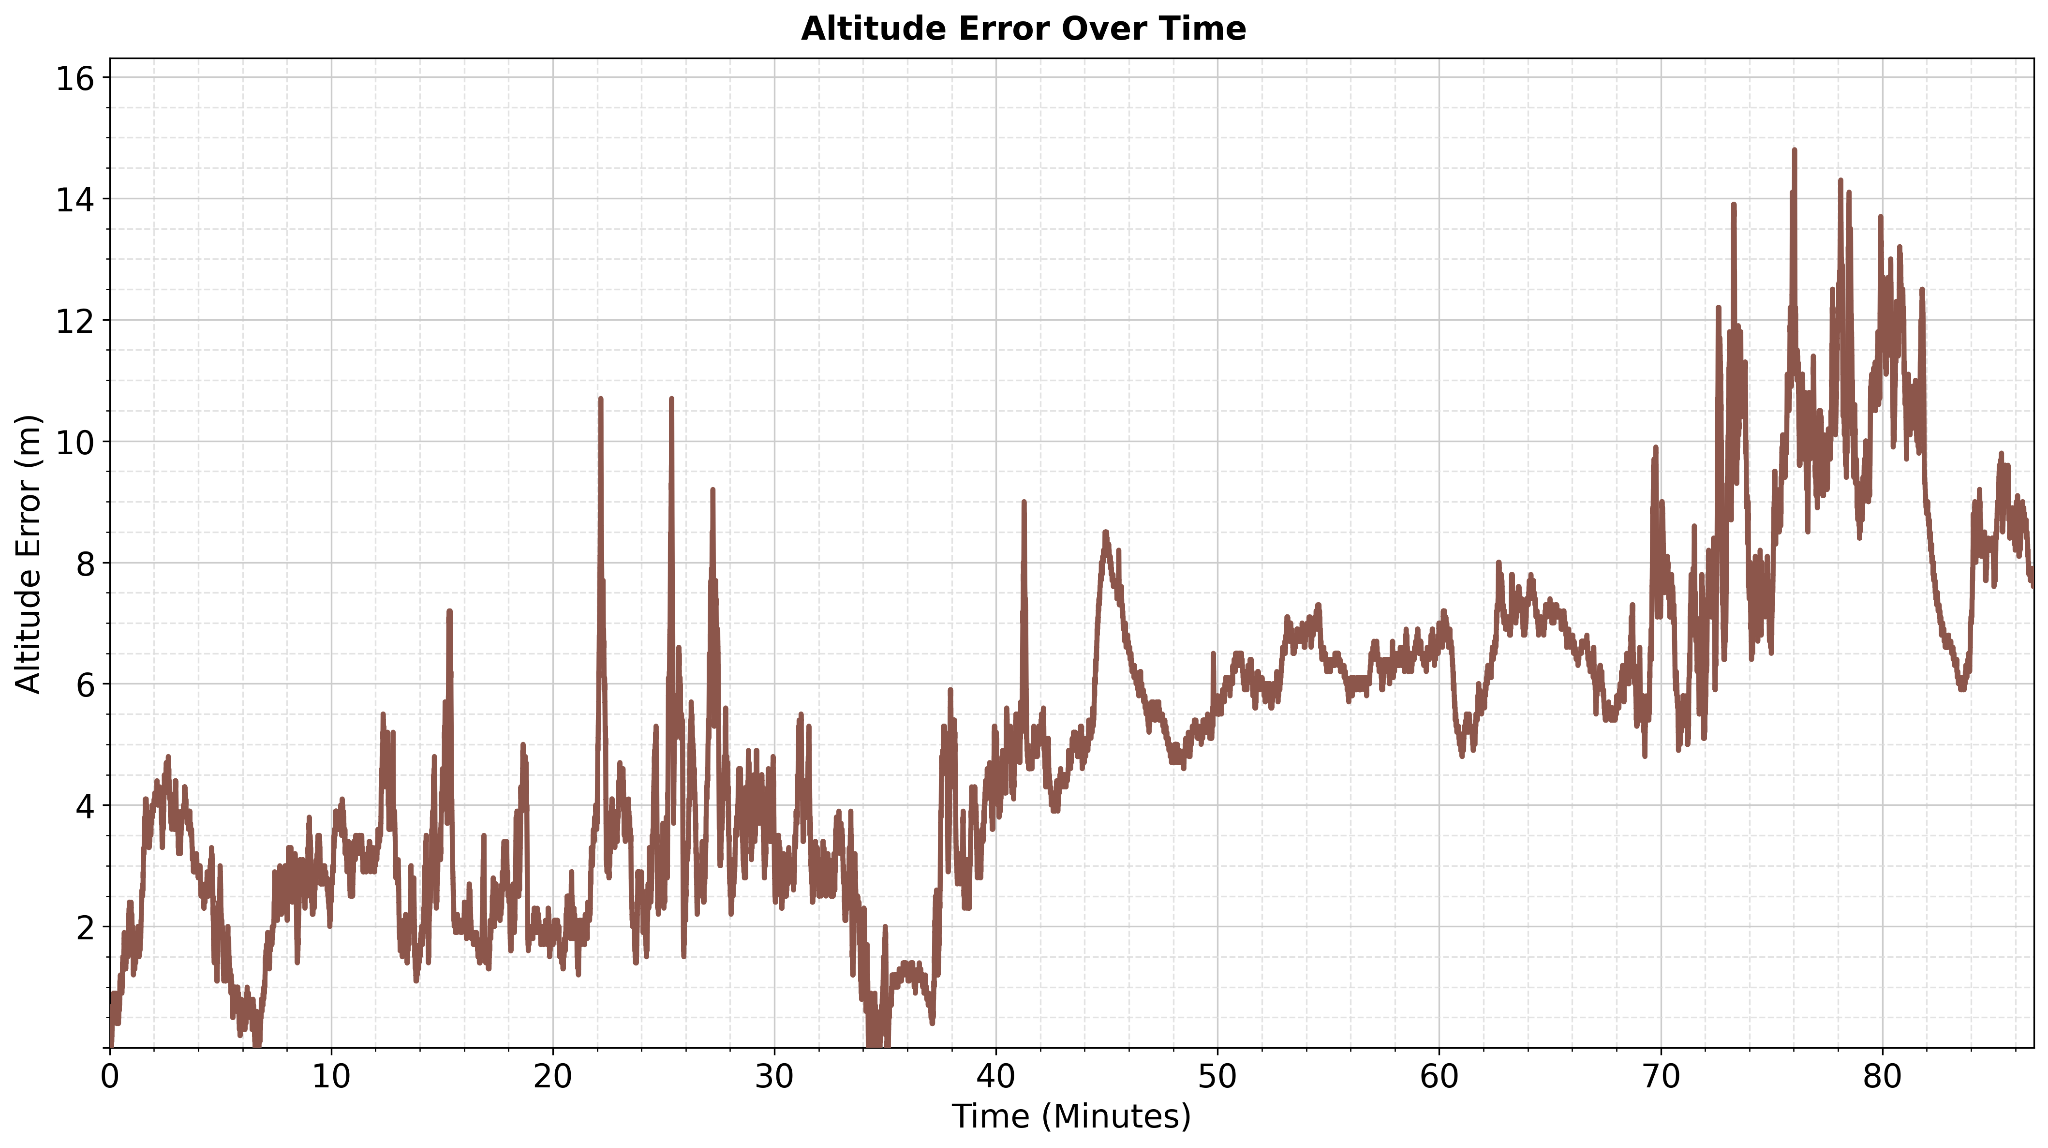 Altitude Error over Time |
Test Statistics
Table 1 : %DT Error Statistics
Distance Travelled (Km) | Drift Error (Meters) | %DT Error |
5 | 217.34 | 4.35 |
10 | 271.38 | 2.71 |
15 | 296.16 | 1.97 |
20 | 353.27 | 1.77 |
25 | 322.95 | 1.29 |
31.4 | 254.61 | 0.81 |
Table 2 : Drift Over Time
Time (Minutes) | Error (Meters) |
10 | 158.22 |
20 | 275.69 |
30 | 304.97 |
40 | 310.63 |
50 | 291.87 |
60 | 303.45 |
70 | 363.29 |
80 | 262.68 |
86.84 | 254.61 |
Author : Aniket Kamat (Lead: Data Fusion Group, Aeron Systems)
Watch the Short Teaser → Link
Watch the Full Navigation Challenge → Link
Please reach out to www.aeronsystems.com/contact for more details