Pollux 3 PLX3-N
Micro-Miniature Inertial Navigation System
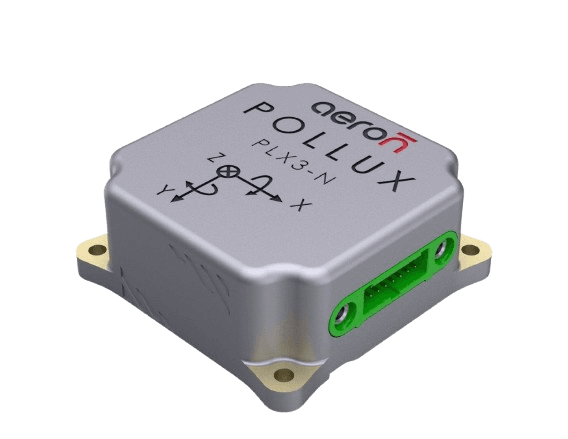
Aeron's PLX3-N is a family of highly compact MEMS-based Inertial Navigation Systems, running an Extended Kalman Filter for near-tactical performance in a package small enough for UAVs, UGVs, and other unmanned systems where size and power are tightly constrained.
Overview
Aeron's PLX3 is a family of highly compact MEMS-based Inertial Navigation Systems. The system runs an Extended Kalman Filter (EKF), offering near-tactical performance and providing the best estimates of navigation parameters — including position, velocities, attitude, and heading. PLX3-N features tri-axial MEMS solid-state accelerometers, tri-axial gyroscopes, a tri-axial magnetometer for heading measurement, and an integrated multi-constellation GNSS.
PLX3-N is a miniature, low-powered INS well suited for UAVs, UGVs, and other unmanned systems where size is a constraint. This strap-down system is designed to perform in highly dynamic situations, delivering precise attitude, heading, and position information over serial RS232 and UART TTL ports at a navigation output rate of 200 Hz.
Design Highlights
- Extended Kalman Filter sensor-fusion engine
- Tri-axial MEMS accelerometers, gyroscopes & magnetometer
- Integrated multi-constellation GNSS (GPS, GLONASS, Galileo, BeiDou, NavIC)
- Jamming & spoofing detection on the GNSS receiver
- User-configurable dynamic range up to ±2000°/s and ±40 g
- Weighs ~38 g — built for size-constrained unmanned platforms
How Pollux 3 Processes Sensor Data
Sensor and GNSS inputs are fused in real time through Aeron's Extended Kalman Filter to deliver stable position, velocity, attitude, and heading estimates.
Engineered for Compact, High-Accuracy Navigation


Technical Specifications
PLX3-N · Datasheet Ver. 1.1 · June 2026
Range
±10/40 g (User Configurable)
Bias Instability *
8 µg
Velocity Random Walk (VRW) *
0.03 m/s/√hr
Noise Density *
50 µg/√Hz
Bias Repeatability
0.15 mg
¹ 1σ accuracy; heading accuracy shown with magnetometer and in dynamic conditions with GNSS. ² GNSS-denied accuracy is a function of elapsed outage time and depends on the accuracy of external speed/airspeed aiding. * Typical / Allan Variance.
Applications
Documents & Resources
Documentation
PLX3-N
PLX3-N Datasheet
Ver. 1.1 · June 2026
Frequently
Asked
Questions
Common questions about the Pollux 3 INS-GNSS.